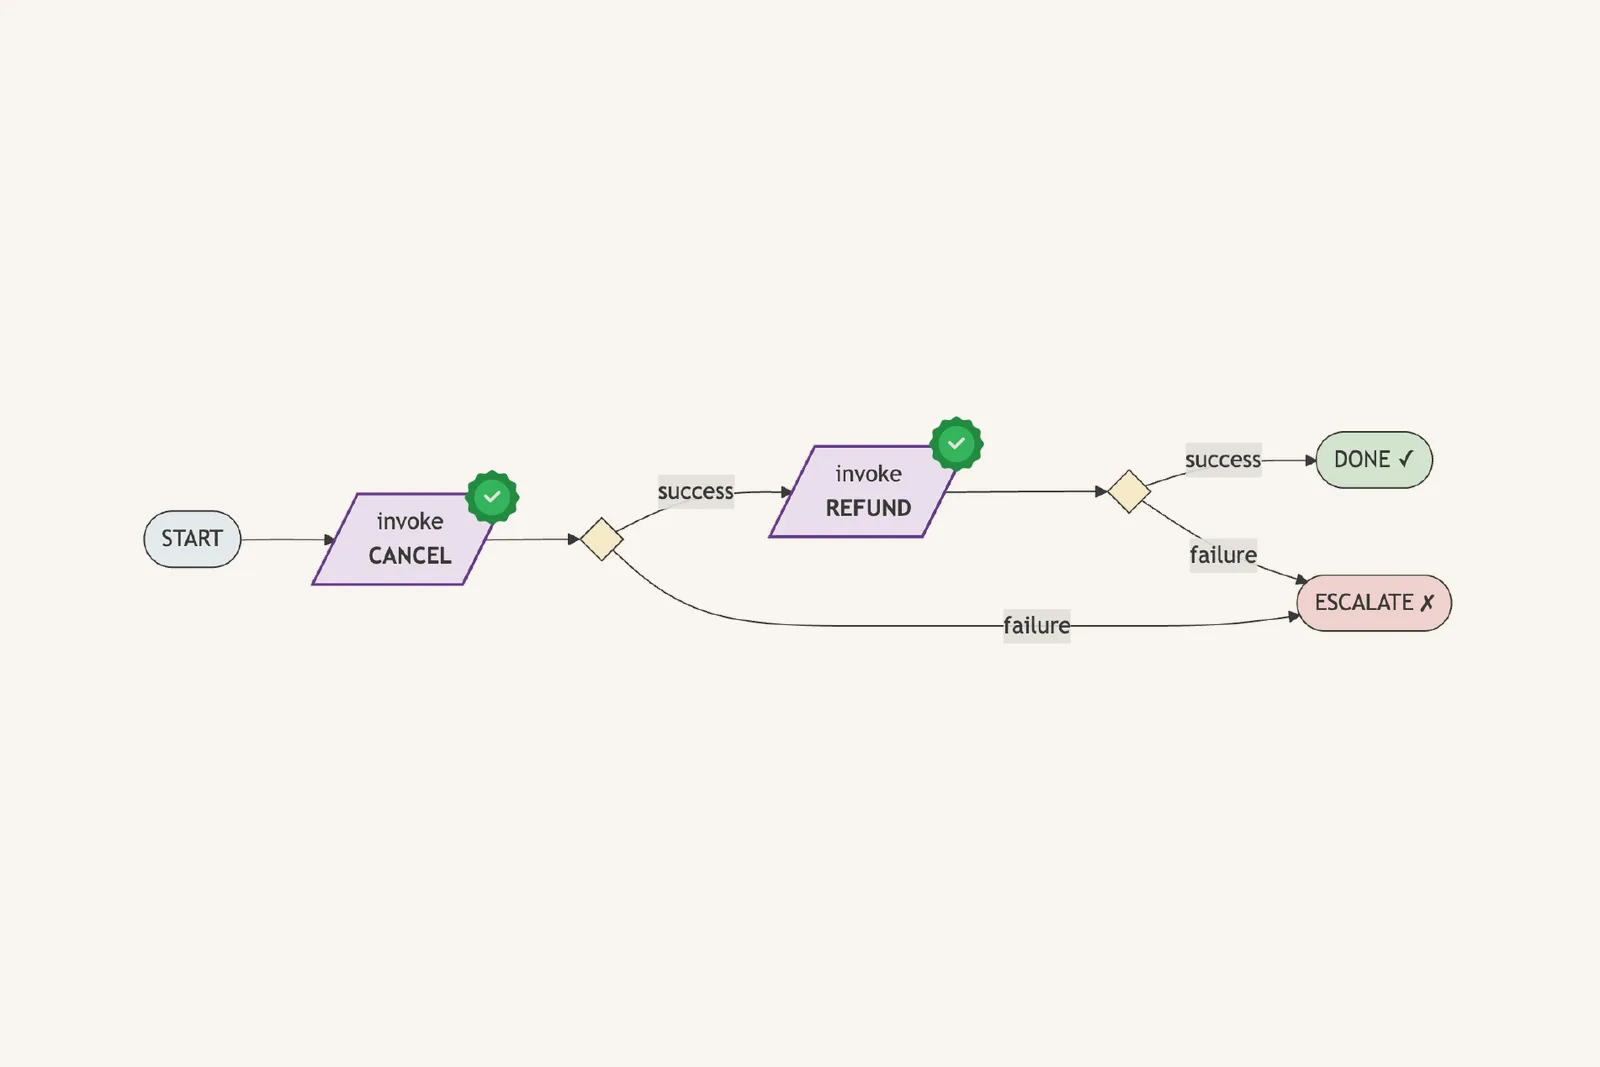
Researchers introduced Soteria, a framework for large language model (LLM) agents that combines formally verified planning with runtime enforcement, in a paper submitted to arXiv on 13 November 2026. The authors address a tension in agents that make multiple tool calls: blocking an unsafe action can avert a policy violation while leaving the agent unable to finish its task.[1]
According to the abstract, the agent first produces a structured plan, which is formally checked against specifications before any tool invocation. During execution, the verified plan is intended both to guide specification-conformant actions and to help the agent recover when an unsafe action is blocked. The abstract describes hierarchical planning but does not explain the verification procedure or the runtime enforcement mechanism in detail.[1]
The authors report results across multiple tool-use benchmarks: Soteria achieved 1.7 times the average task success rate of the best baselines, with no policy-specification violations. These are the authors’ reported results for those benchmarks, not an independent finding about all tasks or deployments. The abstract does not identify the benchmarks or provide enough detail to assess the comparison.[1]
Lead photo: Mike He, Ankush Desai, Sharad Malik, Aarti Gupta · CC BY 4.0.
Sources
Check or correct this page
Verification record
The digest below shows whether the text you are reading matches the published source. It does not show that the reporting is correct. The build computes it from this page's Markdown source and lists it in the site manifest.
773117afca97a32ce5faeb0fdf8acb90a0d691ca6e4d0672a6241135a1f6e441


